Technical Animation
Runtime work in Unreal Engine: correctives, dynamics, and Control Rig.
Hose Cable Dynamics
CCDIK in the Anim Blueprint — hoses bend and follow their attach points with no cloth or physics sim.
Setup — the hose chains solving in the Anim Blueprint, with bones shown.
In game — Arbor's backpack hoses staying connected through live gameplay.
- Each hose is a joint chain solved by its own CCDIK node, from its start joint to an effector at the hose's attach point.
- Transform (Modify) Bone then pins each hose end exactly onto that point, so the connector never drifts off it.
- Left and right hoses run as separate chains, each with its own target location and blend weight.
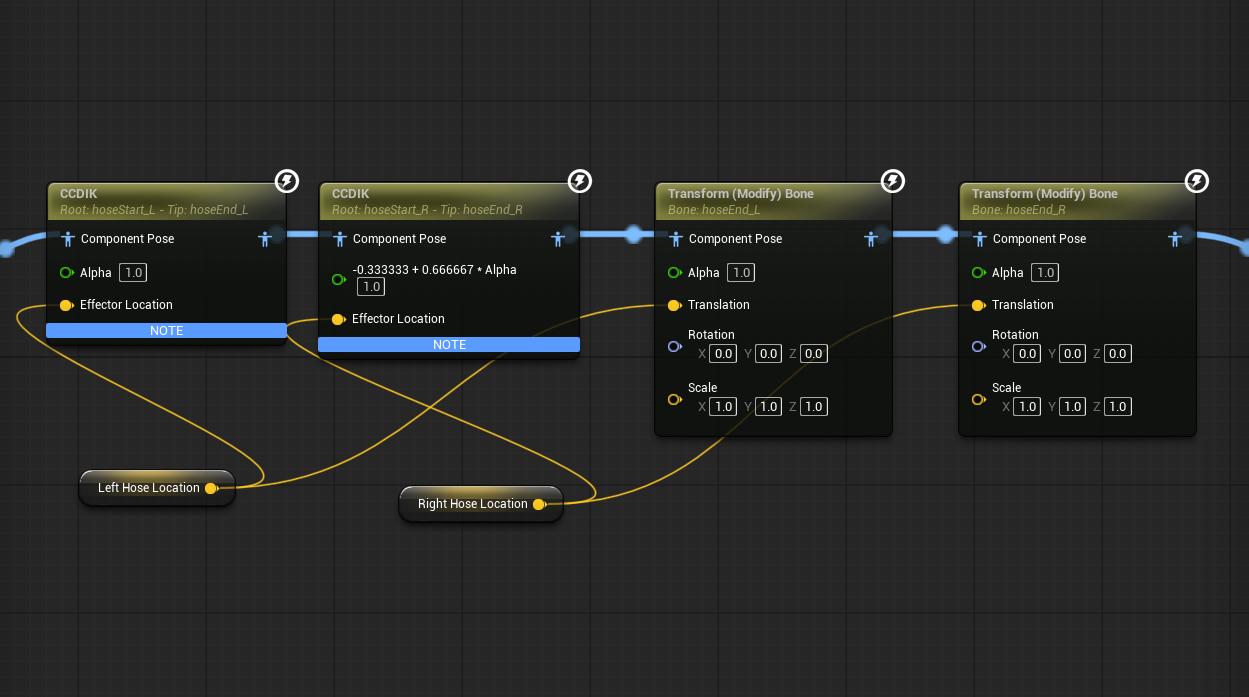
Anim Blueprint graph — click to enlarge.
Knee Pad Correctives
Bone Driven Controllers in the Anim Blueprint — no simulation, near-zero runtime cost.
Before — the rigid pad clips into the thigh as the knee bends.
After — corrective bones ride the knee and clear the thigh.
- The knee's rotation drives three corrective bones on the pad:
- Rotate — follows the knee at 0.5×.
- Push up — 0.05 per degree of knee bend.
- Push out — −0.025 per degree, so the pad slides off the thigh instead of through it.
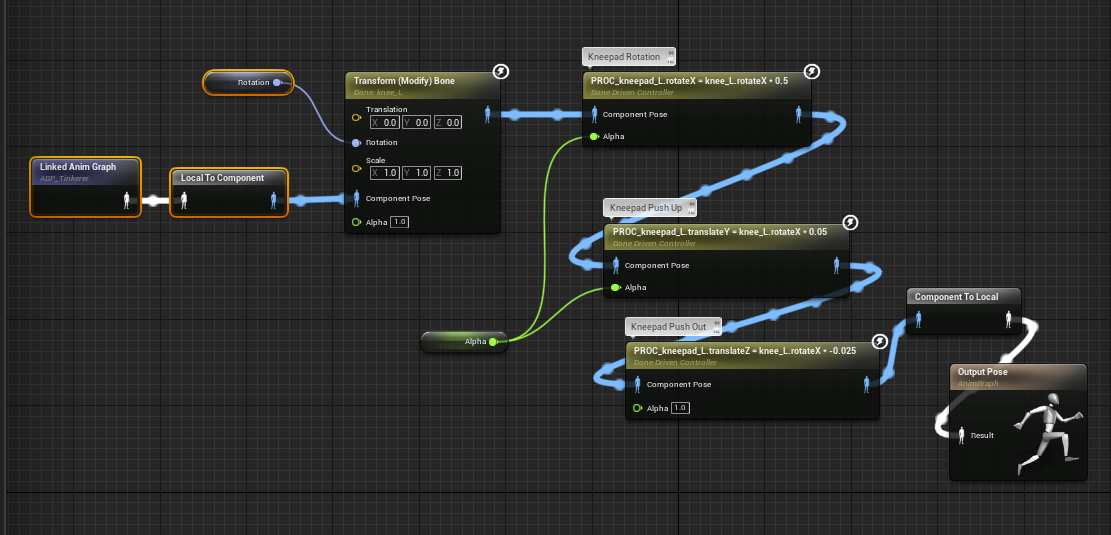
Anim Blueprint graph — click to enlarge.